
Physicl has raised $10 million in seed funding from Inovia Capital to turn high-fidelity 3D environments into training data for robots and physical AI models. Founder Alex de Vigan is repurposing the rendering pipeline built over a decade at nfinite, his e-commerce visualization company, for simulation. The bet matters for business because robot developers still lack scalable ways to train systems that grasp and manipulate real objects.
Seed round and Studio launch for edge cases
De Vigan spent ten years building nfinite, which helped brands and retailers create 3D models of goods for online display. The rise of transformer-based generative imagery pushed that business to change course, while exposing a gap in AI spatial understanding and manipulation. Physicl now applies the same capability for converting incomplete real-world information into accurate geometry, materials and physics to robotics training.
Researchers training physical AI models have seen limited returns from video data and high costs from collecting data through teleoperation. Simulated digital worlds offer an alternative, yet keeping their physics faithful to reality remains difficult. Physicl positions its pipeline as a bridge, transforming unstructured and heterogeneous inputs into representations that preserve shape, surface properties and behavior for model training.
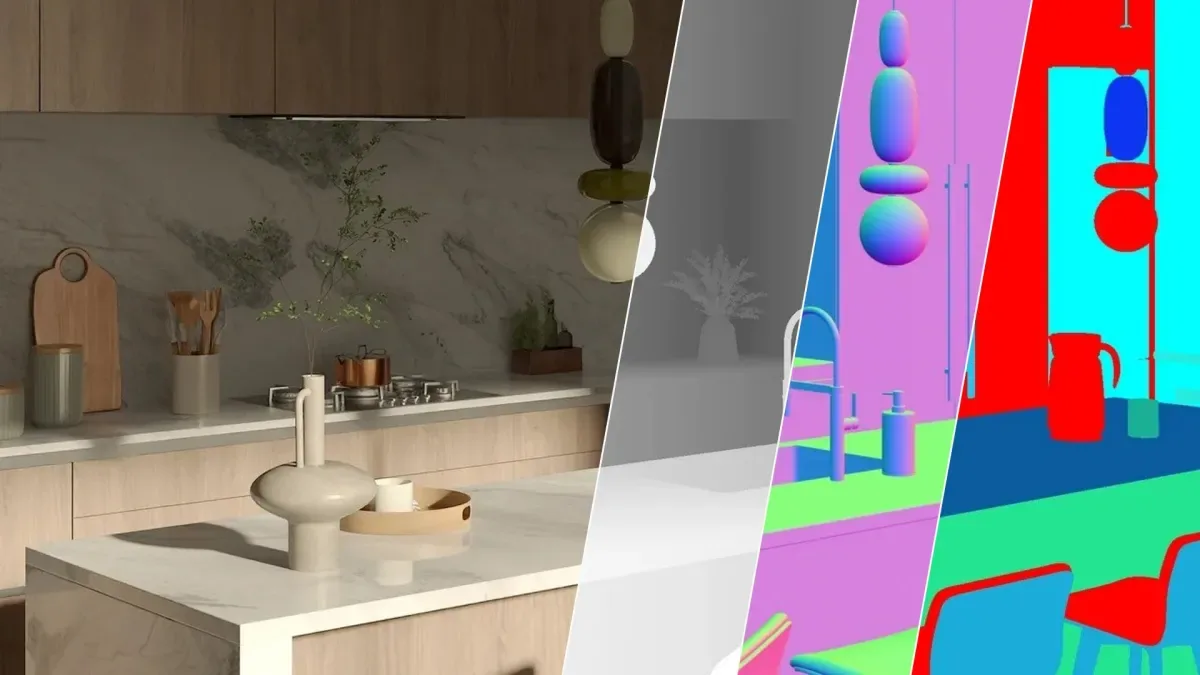
The startup is releasing Studio, a product with 10,000 3D environments and 100,000 object assets for building custom scenes. Users can generate synthetic data aimed at specific failures, such as a robot missing a cup on a cluttered counter or in shadow. The company describes itself not as a one-time data vendor but as tooling for continuous synthetic data generation.
What synthetic 3D means for automation projects
Early customer SpAItial, a world-model builder, used Physicl data to improve fidelity of its simulations generated from 2D imagery. Its latest product, Echo-3, was released last week, and CEO Matthias Niessner linked its performance to high-fidelity synthetic training data. For companies deploying robots in warehouses, retail or light manufacturing, such tooling could shorten the cycle of fixing perception errors without new physical data collection.
De Vigan expects customers to bring trillions of images or millions of hours of LIDAR captures to create billions of training permutations. Niessner, also a robotics professor at the Technical University of Munich, pointed to on-the-fly generation tied to training state, where a system running Claude requests more data as gaps appear. The limitation is curation: manual dataset preparation remains slow, and buyers need to verify physics accuracy, asset coverage and integration with their training stack.
The marker to watch is whether Studio customers move from pilot scenes to ongoing generation linked to model training loops. Repeated orders tied to edge-case libraries and new Echo-class releases would confirm demand for synthetic 3D as infrastructure. If that shift happens, physical AI teams will treat simulation quality as a procurement criterion alongside compute and data labeling.
